B&R and Beckhoff both sit at the high-performance end of machine automation. A PLC is the controller that runs the machine. These two are not interchangeable copies of a generic one. Each is a full way of building a machine: the hardware, the fieldbus (the fast network to the drives and sensors), the motion, the HMI (the operator screen), and the engineering software, designed to work as one system. The right choice depends less on brand loyalty and more on how the machine is built, how your people write software, and who will maintain it for the next decade.
How to read this Written for controls engineers and machine builders. It is not a vendor scorecard. Product lines change. Always check the current catalog, the licenses, and support in your region against your specific machine.
Pick the platform that matches how your machine thinks — not the one that looks familiar in a brochure.
How the controller is built
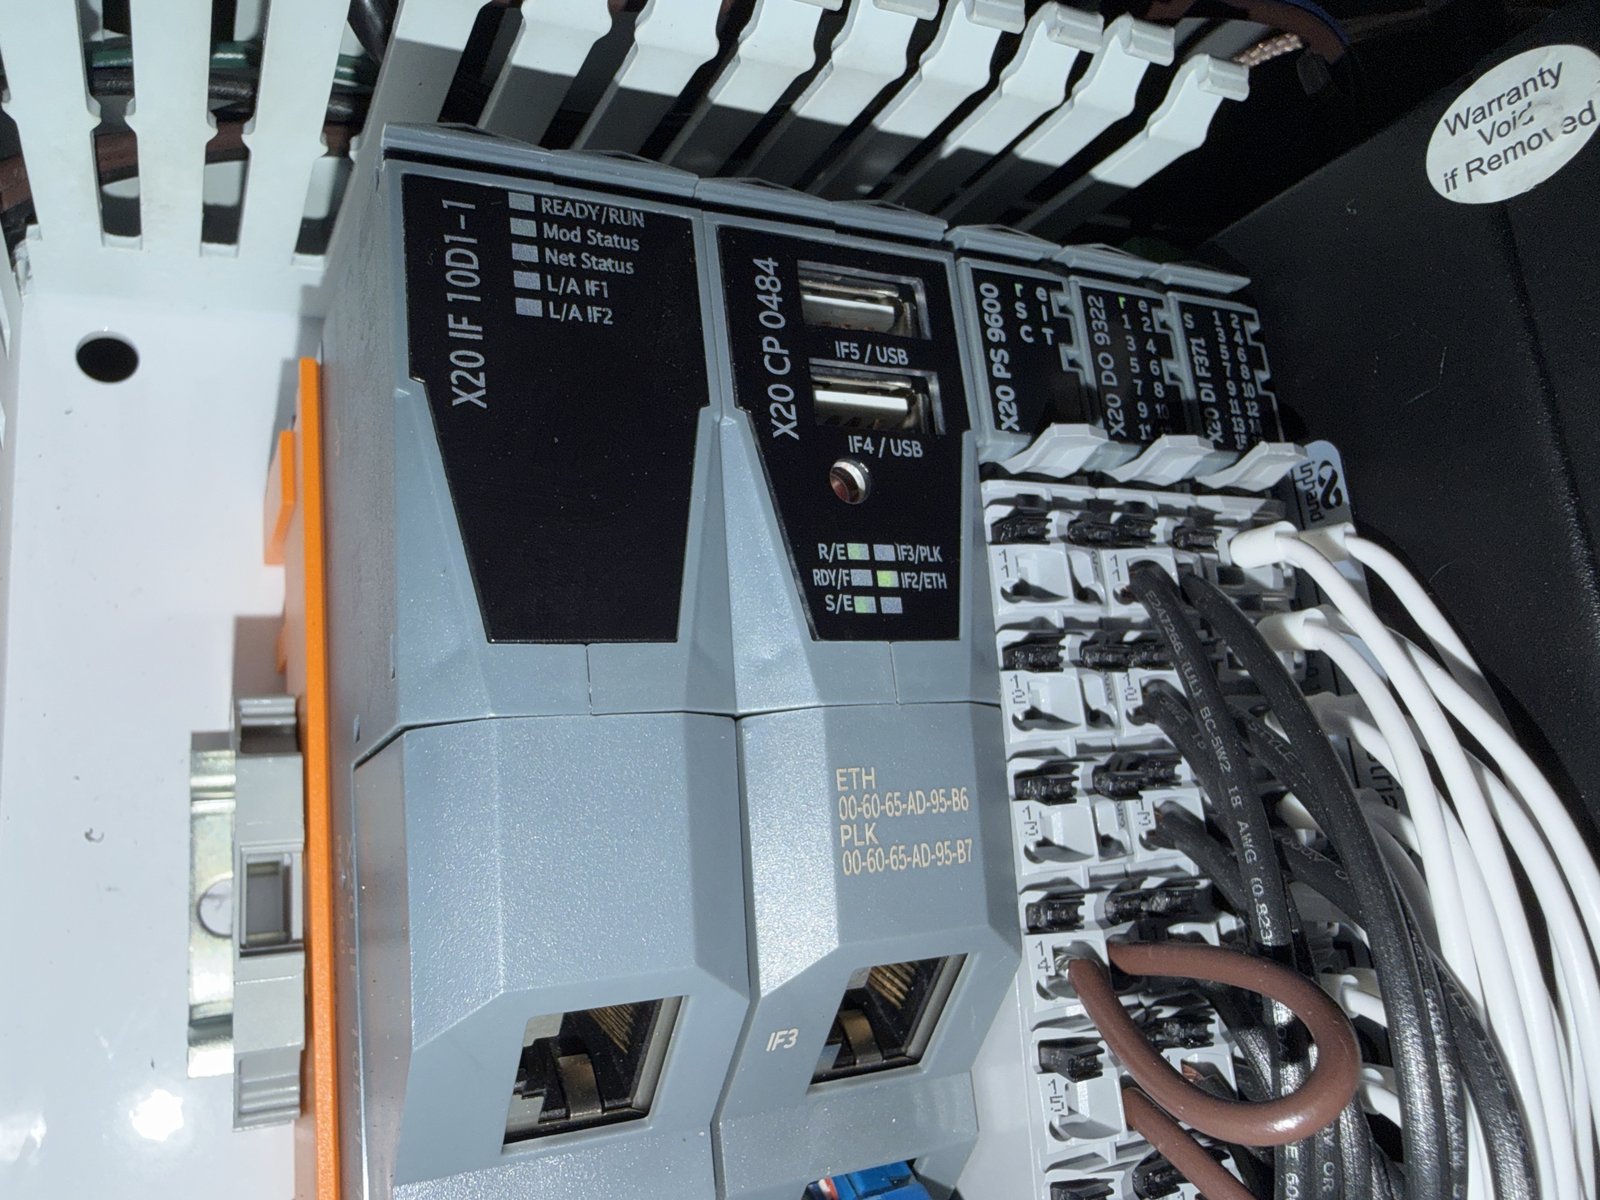
B&R (part of ABB) grew up as a classic machine-automation vendor with a strong PLC and modular input/output tradition. Inputs and outputs are the sensors and the devices the controller turns on and off. The X20 and X90 families, the Power Panel screens, and ACOPOS motion feel like a controller stack built for machines. You can run very capable systems with a clear split between controller, inputs and outputs, drives, and the operator screen, and still use a PC where you need the performance.
Beckhoff is the reference brand for control on a computer. An industrial PC is a hardened computer built for a cabinet. TwinCAT turns that PC, or a smaller computer built into the panel, into the controller that runs on a fixed schedule. A soft PLC (control software on the computer), motion and CNC, safety, and vision can share the same processor. The bet is: computing is cheap, EtherCAT is fast, and software should absorb complexity that used to live in dedicated hardware boxes. EtherCAT is Beckhoff’s machine network.
- Lean toward B&R when the machine wants a traditional controller, modular inputs and outputs, packaged operator screens, and a tight ABB/B&R machine catalog.
- Lean toward Beckhoff when you want room to grow on the computer, software modules on one box, and the freedom to add features without swapping the controller.
Engineering software: Automation Studio vs TwinCAT
Automation Studio is a programming environment built around the machine. Configuration, the IEC 61131 languages (the standard set of controller languages, including ladder, which looks like an electrical diagram), screens, motion, and diagnostics live in one project tree. Many machine-builder teams like the guided hardware setup and the way machine modules map to software units. The learning curve is real. The environment rewards builders who reuse libraries across a family of machines.
TwinCAT 3 sits inside Visual Studio, so it feels closer to a software workstation. IEC 61131, C and C++, a path from MATLAB/Simulink, and a large set of TwinCAT function modules sit next to ordinary Windows habits. Teams with a strong software culture often move faster in TwinCAT. Teams that think in ladder or in structured-text machine blocks may feel more at home in Automation Studio.
- Automation Studio strengths: one project for the whole machine, hardware and software that match, and packaged screen and motion workflows for machine builders.
- TwinCAT strengths: room to extend it, more language choices, software you can buy in modules, and comfort for engineers who already live in Visual Studio.
I/O and field wiring reality
Both platforms offer dense, modular remote inputs and outputs: thin slice modules, analog signal conditioning, and specialty cards. The decision usually comes down to how full the cabinet is, how you run the cable, and how much thinking you push out to the input/output modules.
B&R’s X20 style is excellent for ordinary machine cabinets and for stations spread around the machine. Beckhoff’s EtherCAT Terminal system (the EL and EP module families) is extremely fine-grained and fits a spread-out EtherCAT layout, including IP67 boxes mounted on the machine when the mechanics allow it. IP67 is a housing that keeps out dust and temporary water.
In practice: if your machine builders already standardize on one shape of input/output module across a product line, switching brands is rarely “just a different terminal.” Spares, drawings, and technician habits matter as much as how many channels fit in an inch.
Motion and robotics on the machine
Both vendors are serious about coordinated motion: many axes staying in step, electronic cams (a software version of a mechanical cam), robot math, and drives that include safety.
B&R / ACOPOS is often favored in packaging, printing, and high-speed machines where cam tables, registration (lining a print or a cut up with the product), and combined mechanical-and-electronic modules are first-class. The motion story is tightly tied to Automation Studio’s model of the machine.
Beckhoff motion — point-to-point and CNC, robot libraries, and other companies’ drives on EtherCAT — is flexible: many axes, many drive brands, and the ability to keep advanced motion math next to the control logic on the same industrial PC. If your machine mixes custom mechanics with a free choice of drive, Beckhoff’s openness is a real advantage.
Communication protocols: what each platform actually speaks
The brand and the machine network travel together. B&R’s center of gravity is Ethernet POWERLINK, usually just called POWERLINK. Beckhoff’s is EtherCAT. Both also speak ordinary TCP/IP and OPC UA for engineering, the operator screen, and plant IT. OPC UA is a vendor-neutral way to read a controller. Both can sit next to a Rockwell plant through an EtherNet/IP gateway when you plan that up front. EtherNet/IP is the network most US Rockwell plants already use.
Figures below are typical published ranges Cycle time and how much data fits depend on how big the block of signals is, how many devices are on the network, the layout, and how loaded the controller is. Treat the vendor datasheet and your own sizing as the source of truth for a given machine. Brochure extremes are not that.
B&R / ABB machine stack
- Ethernet POWERLINK — the machine network with a fixed schedule, used for X20 and X90 inputs and outputs, ACOPOS drives, and motion that has to stay in step. One managing node gives each controlled node a time slot, started by a start-of-cycle message. Commonly deployed on 100 Mbit/s Fast Ethernet. Gigabit POWERLINK variants exist for heavier loads.
- openSAFETY — the safety protocol commonly carried over POWERLINK for safe inputs, outputs, and drives.
- OPC UA — the usual path up to the plant screens, to MES (the system that tracks production orders), and to the data shared between the plant and the office. OT is the plant side of that split. It often runs alongside Automation Runtime, B&R’s controller software.
- OPC UA FX (Field eXchange) — a newer standard for controllers and devices to share one description. B&R now publicly positions controller-to-controller FX on industrial PCs, panel PCs, and PLCs, through the OPC UA FX Technology Package in Automation Studio and Automation Runtime. Early controller-to-device hardware includes the ACOPOS M4 (a servo that speaks FX) and the X20BC008T bus controller on Ethernet that supports TSN. TSN, time-sensitive networking, reserves the wire so important traffic is not delayed. This is an open path across vendors. It is not an overnight replacement for every POWERLINK machine network. Device-level FX is still rolling out across the industry. Ask for the Automation Studio, Automation Runtime, and technology-package versions, and for the certificate on that exact catalog item. See OPC UA FX explained.
- TCP/IP / UDP — engineering (Automation Studio), screens, and file or service traffic on ports that are not on the real-time schedule, or on a separate network card.
- PROFINET and other plant networks — relevant in broader ABB plants and plants with several brands. PROFINET is the network Siemens machines use. Many B&R machines stay on POWERLINK and bridge outward with OPC UA, a gateway, or plant Ethernet, rather than making PROFINET the motion network.
Published POWERLINK performance is typically in the hundreds of microseconds for repeating machine traffic — often cited around 200–400 µs cycle times for high-performance setups, with many packaging and assembly machines running comfortably in the sub-millisecond to low-millisecond band depending on axis count and input/output load. The variation in that timing is designed for hard real-time motion, not for ordinary plant Ethernet that sends data whenever it can. For machine builders updating an existing design, the practical story is usually POWERLINK and openSAFETY for proven machine timing, with OPC UA or OPC UA FX on Ethernet for the screens and for the newer open exchange between controllers and devices. It is not a rip-and-replace of one by the other.
Beckhoff / TwinCAT stack
- EtherCAT — the built-in real-time machine network (IEC 61158 Type 12). “Processing on the fly” means one Ethernet frame is updated by each device as it passes, which keeps the delay low even with many devices. Standard EtherCAT is 100 Mbit/s. EtherCAT G and G10 raise the wire toward 1 Gbit/s and 10 Gbit/s for cameras, high channel counts, and large blocks of signals.
- ADS (Automation Device Specification) — Beckhoff’s own language for TwinCAT talking to a device, or TwinCAT talking to TwinCAT: variables, services, and diagnostics. ADS commonly rides TCP/IP to engineering PCs and operator screens, and it can also ride the EtherCAT network itself.
- OPC UA — TwinCAT’s OPC UA server and client for connecting to the plant and to office systems.
- TCP/IP — the Windows and engineering side: web diagnostics, file transfer, and ADS over TCP.
- Safety over EtherCAT (FSoE) — functional safety, the certified way to stop safely, for TwinSAFE inputs, outputs, and drives on the same family of wire.
Published EtherCAT figures commonly cite repeating updates down to the tens of microseconds for small blocks of signals. Vendor literature often highlights about 50 µs and below in optimized cases. Real machines are frequently engineered in the 250 µs to 1 ms range for multi-axis motion and spread-out inputs and outputs. Shared clocks give nanosecond-class synchronization across the devices. That is one reason EtherCAT is a default for motion with many axes.
Protocol snapshot
| Protocol | Typical link speed | How fixed the timing is | Motion fit | Primary vendors / home |
|---|---|---|---|---|
| Ethernet POWERLINK | 100 Mbit/s common; Gigabit variants | Hard real-time, repeating, with a time slot for each device | Excellent for synchronized machine motion | B&R / ABB machine automation; EPSG ecosystem |
| EtherCAT | 100 Mbit/s standard; G / G10 for 1–10 Gbit class | Hard real-time; distributed clocks | Excellent; multi-vendor drives/I/O common | Beckhoff TwinCAT; wide EtherCAT Technology Group ecosystem |
| ADS | Over TCP/IP or EtherCAT (app layer) | Loose and service-oriented. It is not the machine network | Engineering, the operator screen, TwinCAT services. Not the motion network itself | Beckhoff |
| OPC UA | Ethernet (often Gigabit plant/IT) | Not hard real-time by default. Publish-and-subscribe plus TSN is emerging | Screens, data, and recipes. Not the classic servo network | Cross-vendor (B&R, Beckhoff, ABB, Rockwell peers) |
| TCP/IP | 100 Mbit / 1 Gbit Ethernet | Best effort, unless you engineer priority or TSN on purpose | HMI, engineering, file/services | Universal |
| PROFINET | 100 Mbit / 1 Gbit | A hard isochronous mode; looser real-time and ordinary traffic otherwise | Strong in Siemens-centric machines/plants | Siemens ecosystem; ABB/plant coexistence via gateways |
| EtherNet/IP (CIP) | 100 Mbit / 1 Gbit | Scheduled input/output; clock sync when axes must move together | A good plant standard and many assembly cells. Less of a built-in hard schedule than EtherCAT or POWERLINK when many axes share one network | Rockwell / ODVA; dominant in many US plants |
Speeds and cycle times: how to read the numbers
Link speed and cycle time are related, and they are not the same thing. 100 Mbit/s is still the everyday wire for POWERLINK and classic EtherCAT. Moving to 1 Gbit, or to EtherCAT G or G10, mainly helps when the block of signals, camera streams, or the number of devices push how much data fits. It does not automatically make a poorly sized motion network “faster” if the bottleneck is how the controller’s tasks are written or how often the drives update.
- POWERLINK (typical published): cyclic machine networks often discussed in the ~200 µs–1 ms band; high-performance setups commonly marketed around ~200–400 µs.
- EtherCAT (typical published): small networks can advertise ~50 µs (and lower) cycles; production multi-axis cells frequently land in ~250 µs–1 ms. Distributed-clock sync is a core selling point.
- EtherNet/IP input/output (typical practice): the requested packet interval, how often a device must speak, is often 1–10 ms for ordinary inputs and outputs. Motion with clock sync can go tighter, but the layout and the switches differ from EtherCAT and POWERLINK, which are one wire on a hard repeating cycle.
- OPC UA / TCP/IP: plant and office timescales, tens of milliseconds to seconds for many screen-level uses, unless you deliberately engineer publish-and-subscribe and TSN.
A hard fixed schedule is a property of the machine network. Plant Ethernet is usually a problem of living alongside that network. It is not a second servo network.
| Network | Typical published / practice range | What it is optimized for |
|---|---|---|
| EtherCAT | ~50 µs (small image) to ~250 µs–1 ms (many machines) | Dense I/O + multi-axis sync on one bus |
| POWERLINK | ~200–400 µs high-perf; sub-ms to low-ms common | Deterministic OEM machine + ACOPOS-class motion |
| EtherNet/IP CIP I/O | Often 1–10 ms RPI; CIP Motion tighter with CIP Sync | Plant-standard discrete/process cells, Rockwell stacks |
| OPC UA / TCP services | Screen-level timing, milliseconds to seconds. Not a default servo cycle | Plant screens, production tracking, recipes, diagnostics |
Compared to EtherNet/IP (Rockwell / ODVA)
EtherNet/IP carries ODVA’s CIP (Common Industrial Protocol) over standard Ethernet. ODVA is the group that maintains that standard. Repeating messages move the inputs and outputs. One-off messages handle setup and services. With CIP Sync, clock sync based on IEEE 1588, and CIP Motion, it supports axes that move together inside Rockwell systems. That is a different design from POWERLINK’s time slots or EtherCAT’s frame that each device updates as it passes.
Where CIP / EtherNet/IP differs
- Layout: EtherNet/IP expects familiar switched Ethernet, a star or a tree, sometimes a ring with a backup-cable method. EtherCAT is typically a line or a ring of devices, with little or no ordinary switching in the real-time path. POWERLINK uses one managing node to schedule the others, often with hubs or repeaters built for that protocol rather than a guess at traffic priority.
- How fixed the timing is: EtherCAT and POWERLINK were built as machine networks with a hard schedule. EtherNet/IP delivers predictable input and output on a well-designed network, but many US plants treat it first as the standard for the whole plant and the cell. Motion inside that world can be excellent. It is generally not the same “microsecond block of signals” story vendors publish for EtherCAT.
- Motion: Packaging lines with many axes, and electronic cams, are native strengths of B&R with POWERLINK and Beckhoff with EtherCAT. EtherNet/IP plus CIP Motion is the natural fit when the plant standard is ControlLogix or CompactLogix, Kinetix drives, and FactoryTalk screens — especially for cells that must look and feel like the rest of the Rockwell equipment.
- Where each one shows up: EtherNet/IP dominates many North American assembly plants and process skids where the company standard requires Rockwell. POWERLINK and EtherCAT dominate machine-builder islands that care about cycle time, how many axes fit, and either many drive brands (EtherCAT) or a tightly packaged mechanical-and-electronic kit (B&R). They then bridge upward with OPC UA or an EtherNet/IP gateway for the plant.
Neither choice is “wrong.” What matters for US plants and OEMs:
- What do your drive and input/output partners already support well: POWERLINK, EtherCAT, or CIP?
- How will the machine talk upward: OPC UA, MQTT (a lightweight way to publish readings), an EtherNet/IP gateway, Ignition, or the plant SCADA? SCADA is the plant screens and alarms.
- Do you need a hard fixed schedule on the machine network, or is scheduled EtherNet/IP input and output, plus good engineering, enough for this job?
Both B&R and Beckhoff can expose a clean OPC UA interface and live next to Rockwell or Siemens plant layers if the gateway is designed on purpose. The machine-network choice should not trap how the screens are built. It will shape which drive and remote-input vendors you are locked to.
Licensing, ecosystem, and total cost of ownership
List prices rarely tell the story. Compare:
- Controller or industrial-PC cost against the performance headroom you need
- Engineering software licensing and runtime options
- Drive + motor packages for your axis count
- Training and spare-parts strategy for service technicians
- Regional support and lead times for your build geography
Beckhoff’s PC-based model can look inexpensive at the controller and then grow with TwinCAT software modules and IPC specs. B&R’s packaged machine approach can look denser up front and then win on reduced integration friction for a standard machine family. Model three years of builds — not one prototype — before you standardize.
When to choose which
| Dimension | Lean B&R | Lean Beckhoff |
|---|---|---|
| Controller style | A machine PLC and a modular controller story | An industrial PC, with control software on that PC, as the brain |
| Software culture | Machine-centric Automation Studio projects | TwinCAT inside Visual Studio, plus software modules |
| Motion | High-speed packaging / cam-heavy machines | A mix of EtherCAT drives, with the motion math done in software |
| I/O topology | Classic modular cabinet + machine stations | Fine-grained EtherCAT terminals, or IP67 boxes out on the machine |
| Native machine bus | Ethernet POWERLINK (+ openSAFETY) | EtherCAT, plus Safety over EtherCAT. ADS for TwinCAT services |
| vs EtherNet/IP plants | A machine island, then OPC UA or a CIP gateway up to the Rockwell layers | The same pattern. A wide set of EtherCAT devices, and ADS or OPC UA upward |
| Plant integration | Strong OEM machine package into plant layers | Strong when the plant already has people who can maintain both office software and machine software |
| Standardization bet | One ABB/B&R machine stack across a product line | One TwinCAT/EtherCAT platform with flexible peripherals |
Choose B&R when…
- You are a machine builder standardizing a family of assembly machines and want one kit for the controller, the inputs and outputs, the motion, and the operator screen.
- Your applications lean packaging, converting, printing, or similarly cam/registration-heavy processes.
- Your engineering team prefers a dedicated automation tool over a workflow centered on Visual Studio.
Choose Beckhoff when…
- You want PC-class computing, software modules, and room to grow features in software.
- An open choice of drives and inputs on EtherCAT, from more than one vendor, is a real requirement.
- Your team already thinks in software components and libraries, and can keep an industrial PC patched and backed up.
Choose neither as a religion when…
- The plant standard is Rockwell or Siemens and the “machine island” must speak their language cleanly — evaluate gateways, OEM preferences, and long-term support first.
- You are mid-lifecycle on an existing installed base. Migration cost usually dwarfs catalog comparisons.
How Orgenis approaches the decision
We start from the machine and the people who will live with it: cycle time, how many axes, the safety layout, what the operator screen has to do, the spare-parts plan, and who will change the code after handoff. Then we map that to what each platform is good at.
If you are picking a platform for a new machine line, planning a controls refresh, or want a second set of eyes on TwinCAT versus Automation Studio, Orgenis can run a focused controls audit and write a decision memo your stakeholders can actually use.
Discuss a controls platform decision or plant automation roadmap with Orgenis.